春游车遇到路口行人。机器看见一个人影,为什么还不能算会安全开车?The trip vehicle meets a pedestrian at an intersection. Why is detecting a person not enough for safe driving?
第 1 步:感知与定位Step 1: Perception and localization
先弄清自己和周围在哪里。First locate the vehicle and its surroundings.
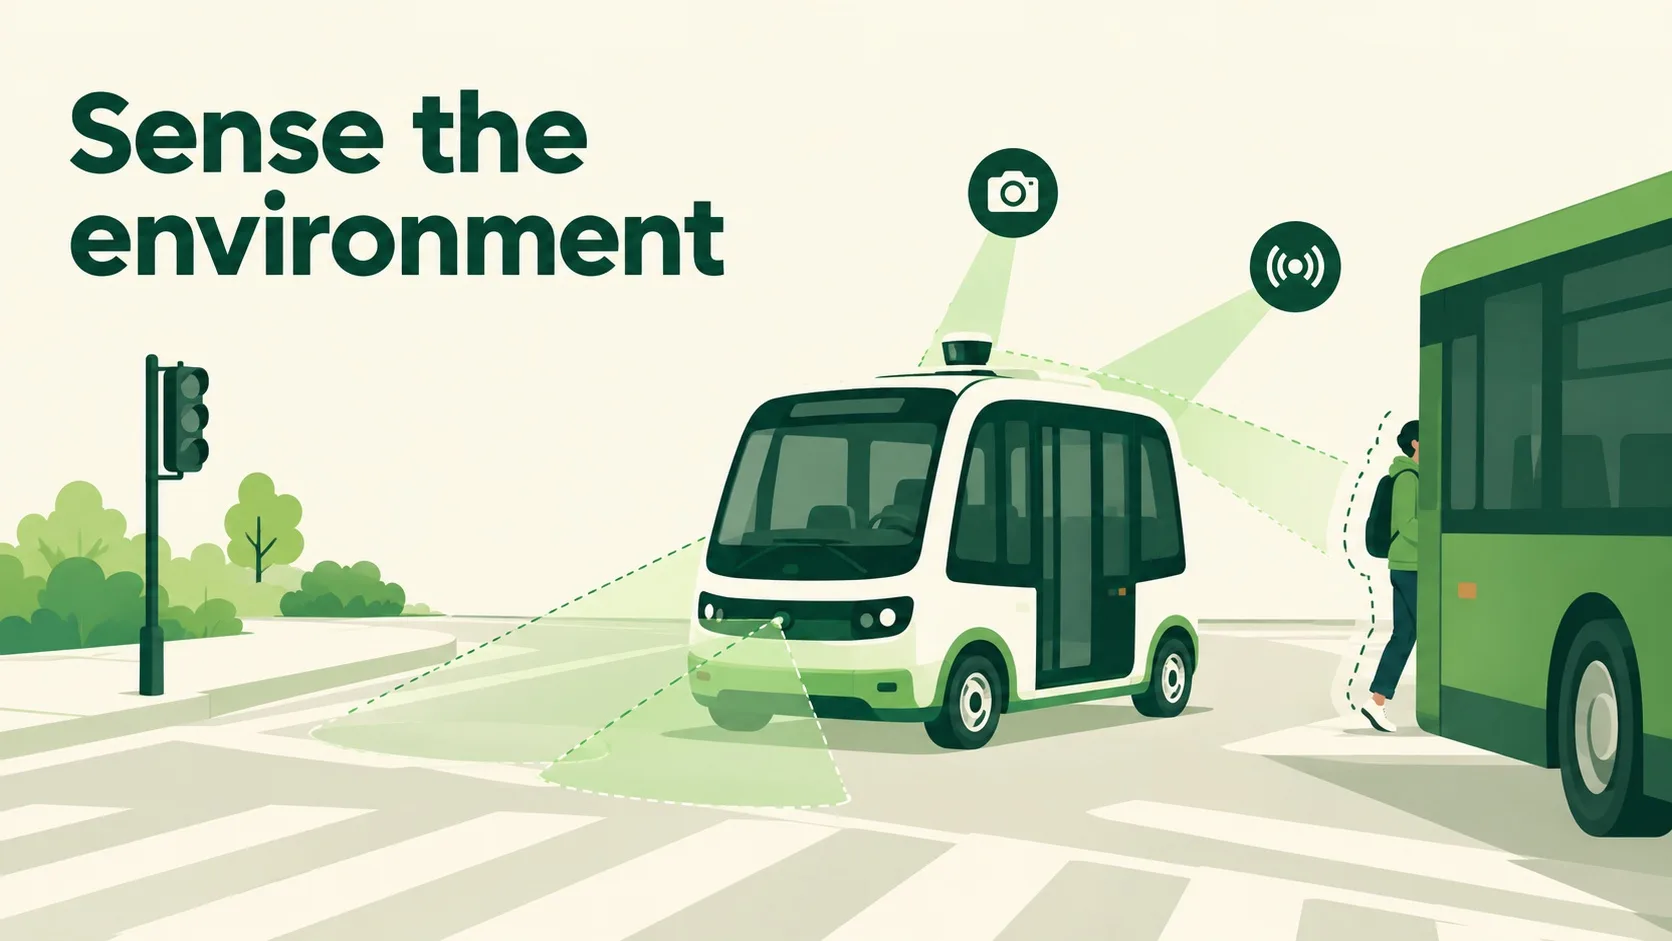
传感器提供周围的测量。摄像头、雷达等各有特点。系统需要估计道路、车辆和行人的状态。定位则估计车在地图或环境中的位置。雨雾、遮挡和反光可能增加不确定性。识别出目标,不代表它的位置和运动一定估得准。Sensors provide measurements of the surroundings. Cameras, radar and other sensors have different strengths. The system estimates the state of roads, vehicles and pedestrians. Localization estimates its own position. Fog, occlusion and reflections can increase uncertainty. Detecting an object does not guarantee its location or motion is estimated accurately.
第 2 步:预测、规划与控制Step 2: Prediction, planning and control
知道现在的位置,下一秒呢?Knowing present positions, what happens next?
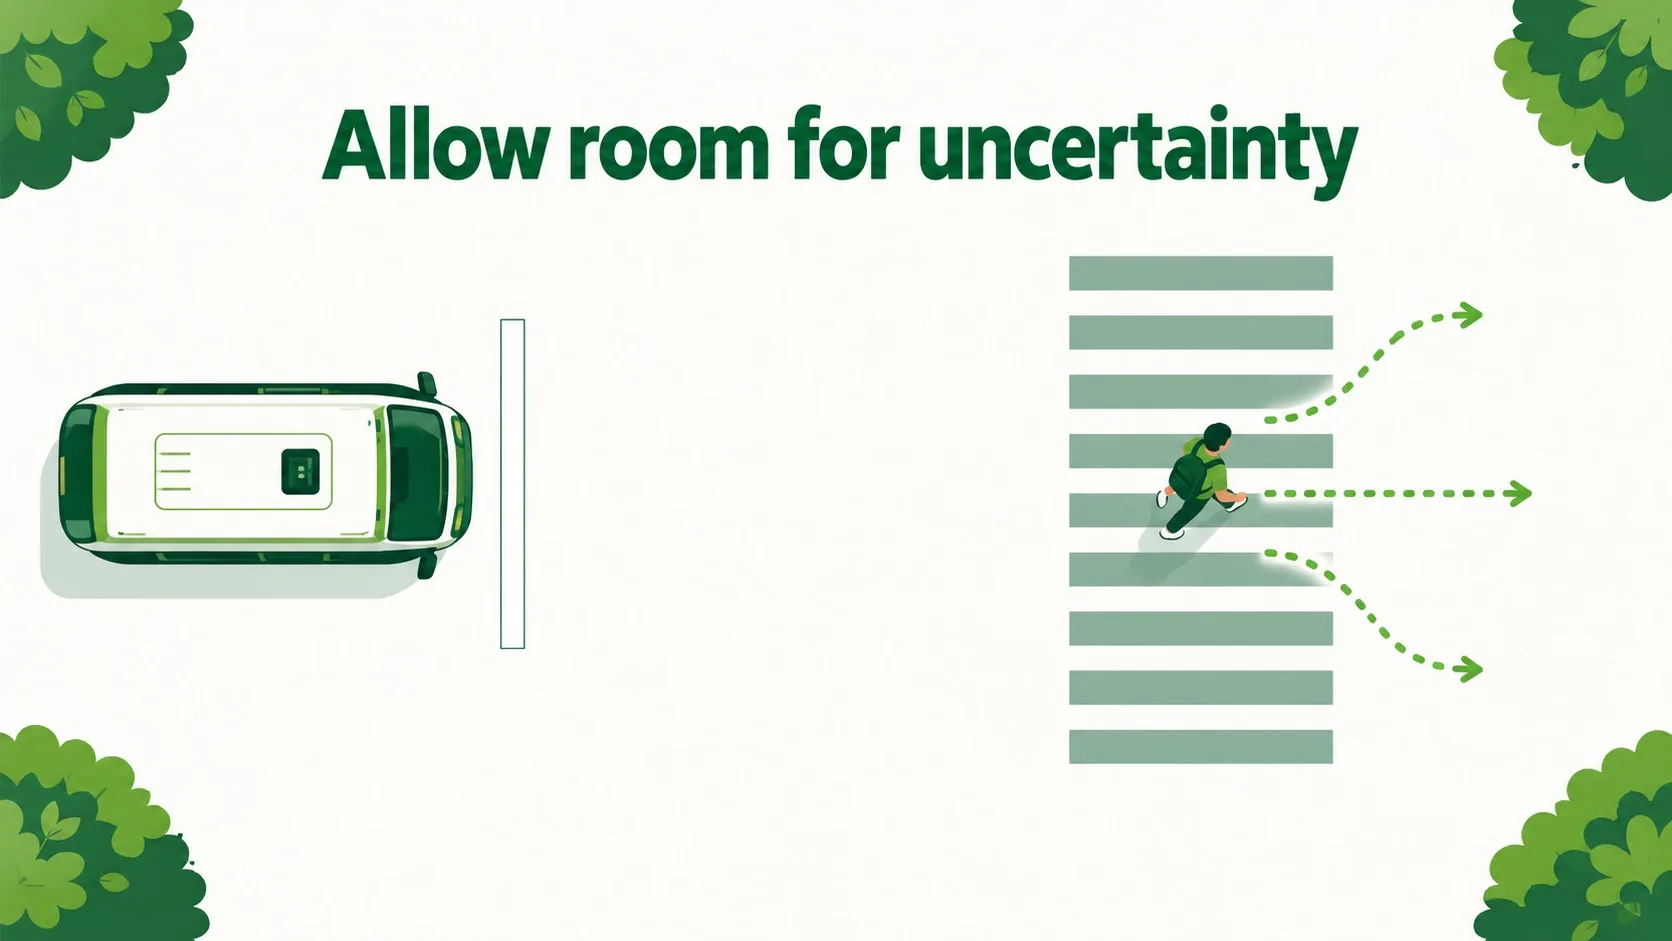
系统还要预测他人可能怎样移动。规划选择路线和速度,控制执行转向与制动。行人可能停下,也可能继续走。规划需留出空间应对变化。模拟里,反应期间也会继续前进。速度变大,停车距离通常增加,不能只看刹车动作有没有触发。The system predicts possible motions of others, plans a path and speed, and controls steering and braking. A pedestrian may stop or continue. Plans need room for uncertainty. In the simulation the vehicle travels during response delay as well as braking. Higher speed generally lengthens stopping distance; triggering a brake alone is not enough.
第 3 步:能力有运行边界Step 3: Capabilities have operating limits
什么地方都能自动开吗?Can automation drive everywhere?
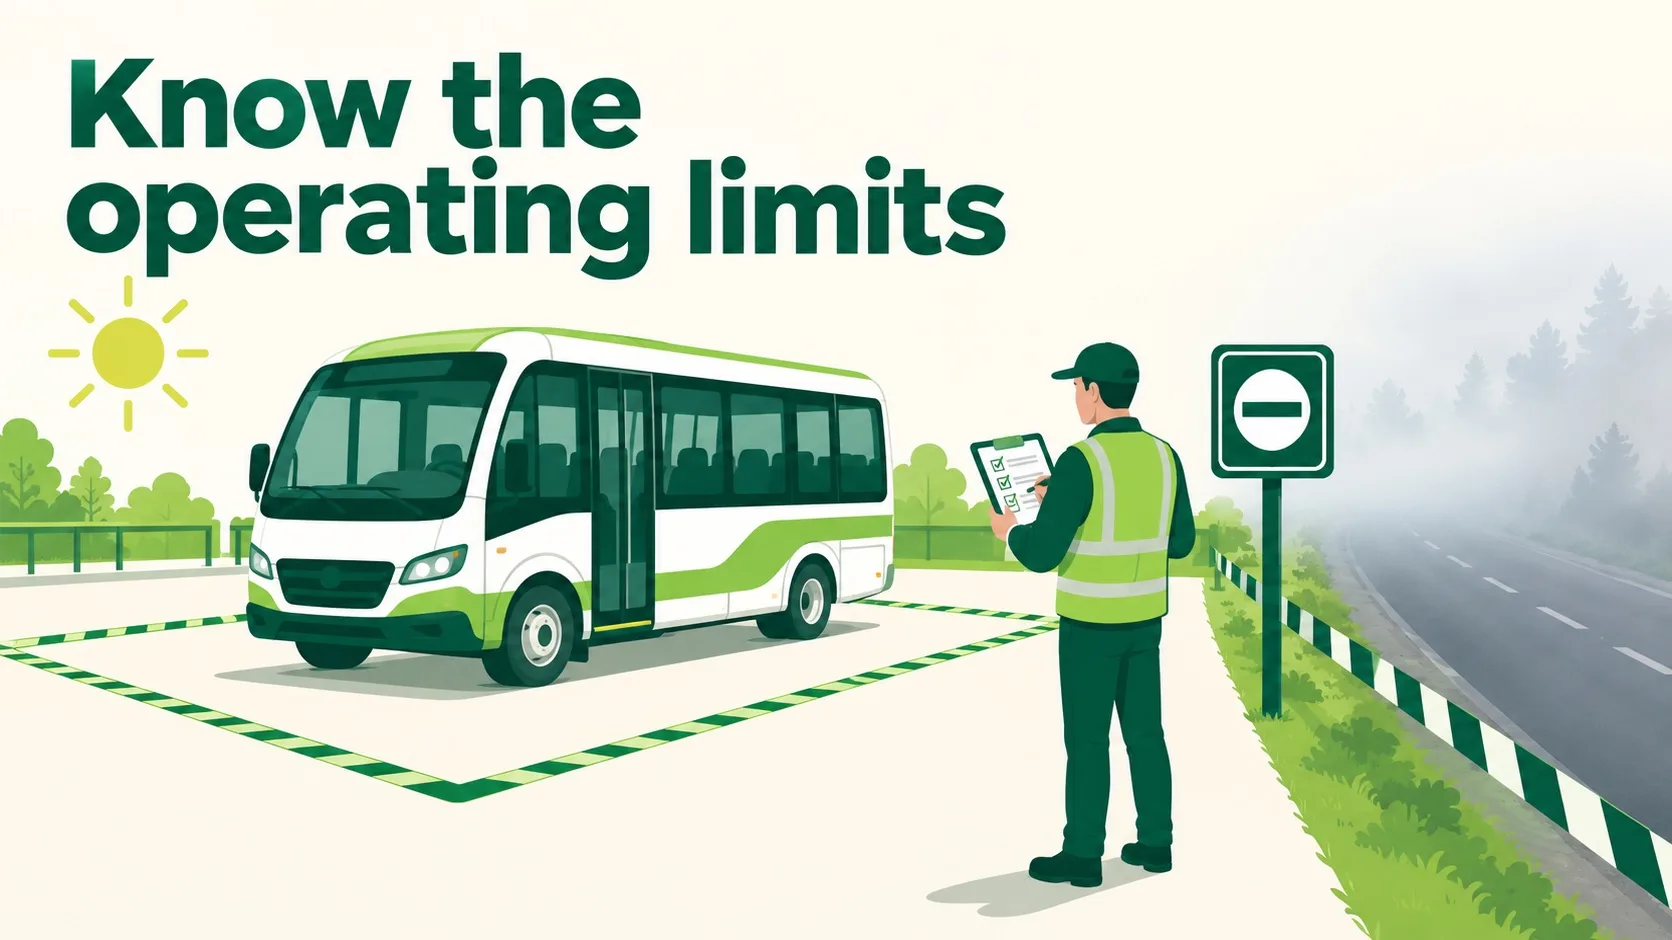
系统能力取决于设计和运行条件。某些道路或天气超出适用范围。驾驶辅助与高等级自动驾驶也不同。是否需要驾驶员持续负责,必须按具体系统要求判断。小禾不会把宣传视频当安全证明。测试、故障处理和适用范围,都需要明确。Capabilities depend on design and operating conditions. Some roads or weather may be outside the supported domain. Driver assistance differs from higher automation. Responsibility and required supervision depend on the specific system. A promotional video is not safety evidence: testing, fallback behavior and operating limits must be explicit.
🎮 停车距离实验场🎮 Stopping-distance experiment
调节速度,在不同视距下停在线前。只用于理解模型,不能用来设定真实驾驶速度。Adjust speed to stop before the line under different visibility limits. This teaching model must not set real driving speeds.
一句话记住它:Remember: 自动驾驶要串起感知、决策和控制,并处理不确定性。Automated driving links sensing, decisions and control while handling uncertainty.
感知结果带有不确定性。Perception involves uncertainty.反应和制动都需要距离。Response and braking both consume distance.必须明确系统适用范围。The system’s operating domain must be clear.
 Back to tree